Open to new roles
03 · Underwater robotics · interfaces + embedded systems
Robotics co-op · 2022–23
Making robotic fleet operation more concrete for the people using it.
Robotics co-op work spanning robot-operation interfaces, embedded communication, and mechanical subsystem integration for underwater robots.
Role
Robotics co-op · 2022–23
What I built
Developed robot-operation interfaces using HTML, Flask, and sockets.
Selected evidence
Fleet-operation interfaces
The problem
On a startup-style research team, the work connected the tools people used to operate robots with the communication and mechanical details that made the fleet usable.
Technical ownership
- 01Developed robot-operation interfaces using HTML, Flask, and sockets.
- 02Supported teleoperated and autonomous robot workflows with embedded C and MicroROS communication.
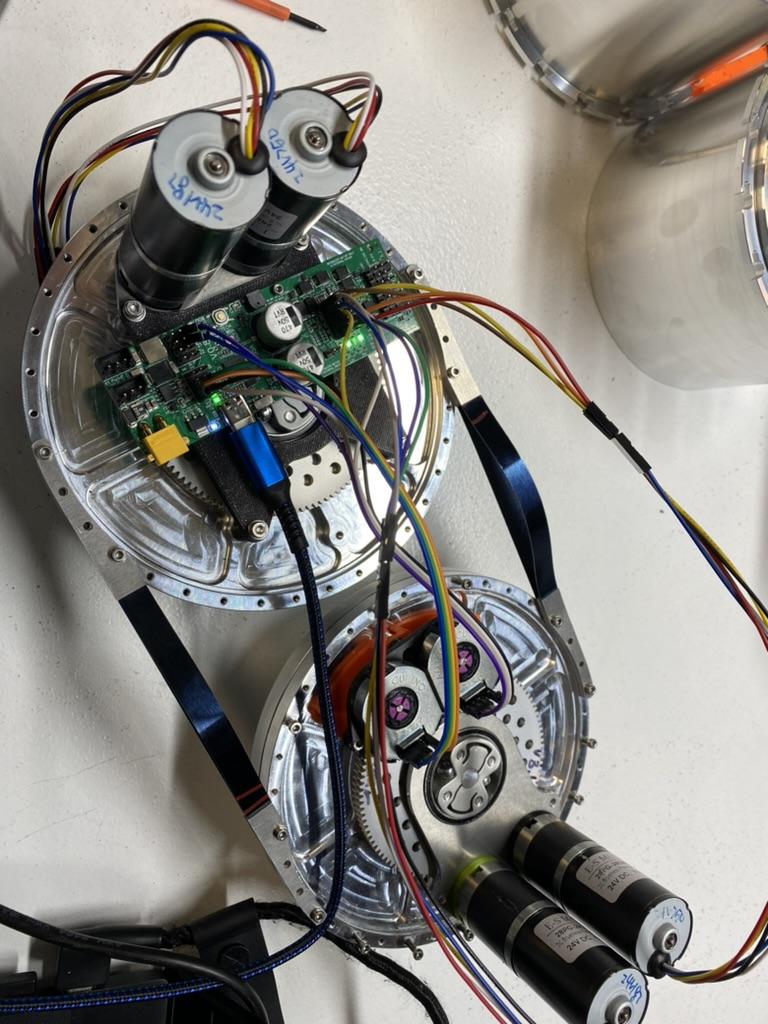
- 03Contributed to planetary-gearbox design and broader subsystem integration.
System architecture
Operator interface → sockets and embedded communication → teleoperated and autonomous fleet workflows.
Evidence + outcome
Tools + systems
In the work
What the work actually looked like.
The hardware, measurements, and interfaces behind the short version.