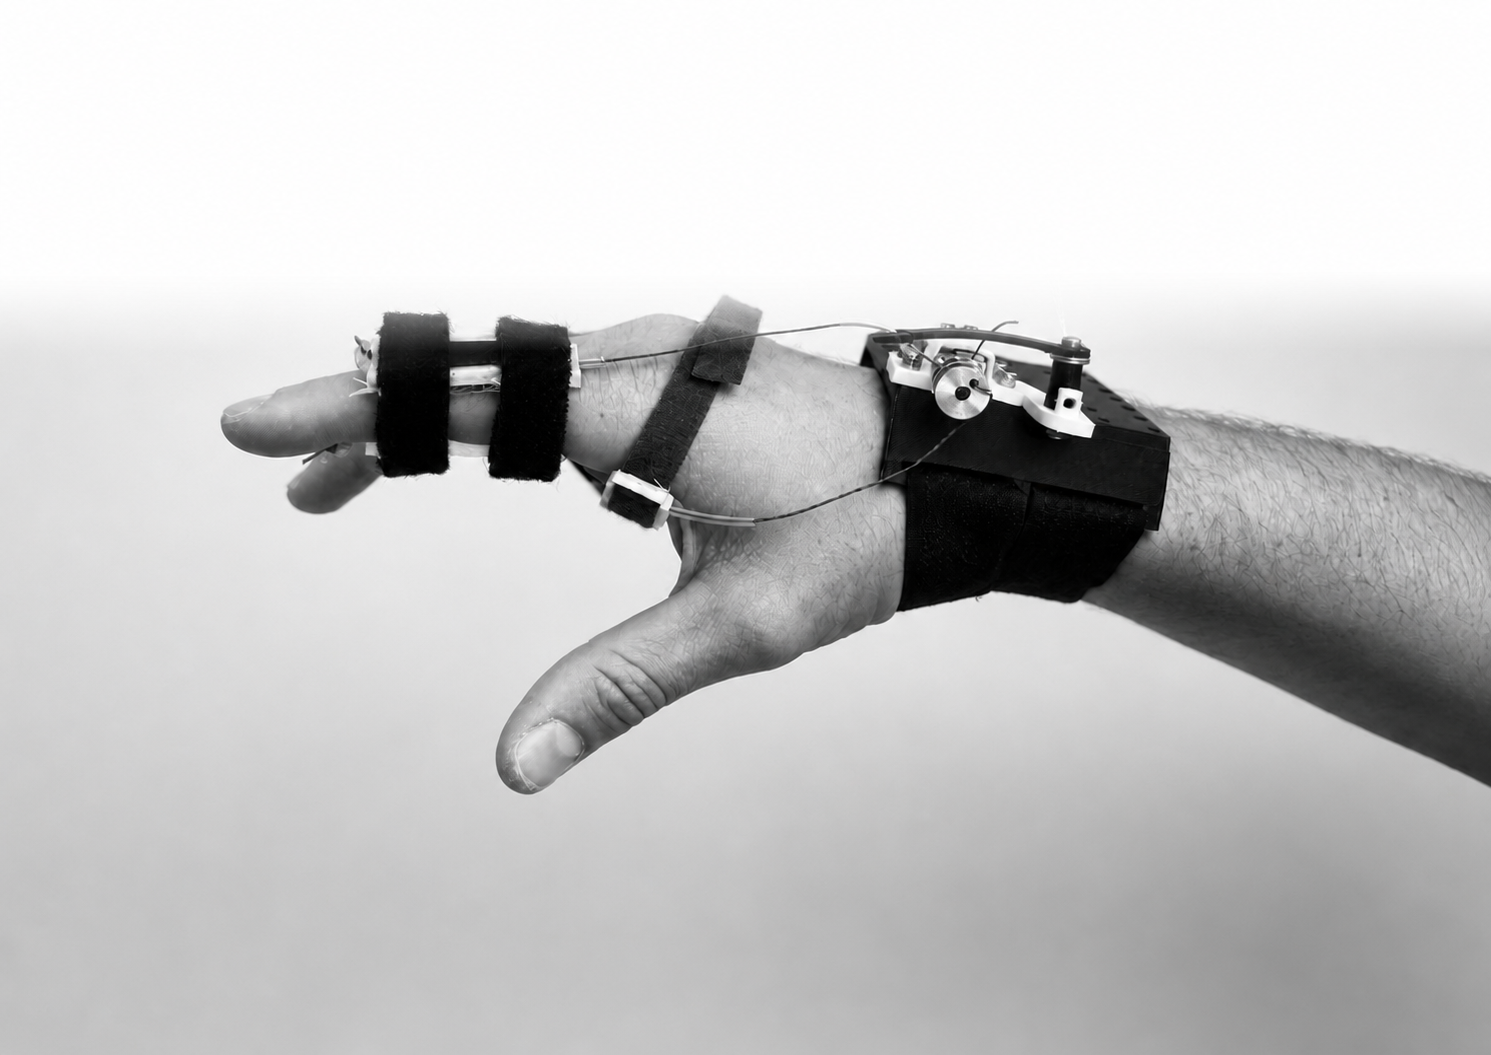
01 · Wearable rehabilitation robotics · modeling + evaluation
M.Sc. thesis · 2026
Wearable finger-actuator thesis
Modeled, built, and tested a wearable finger actuator through rigid-fixture validation and on-hand trials.
Open to new roles
Selected work
Selected engineering work across wearable robotics, field sensing, embedded systems, and force-aware automation.
01 · Wearable rehabilitation robotics · modeling + evaluation
M.Sc. thesis · 2026
Modeled, built, and tested a wearable finger actuator through rigid-fixture validation and on-hand trials.

02 · Agtech robotics · sensing + data quality
Robotics co-op · 2025
Integrated thermal and GPS sensing, then curated representative samples from a large field-image dataset.

03 · Underwater robotics · interfaces + embedded systems
Robotics co-op · 2022–23
Built fleet-operation interfaces and supported embedded communication and drive-module integration.
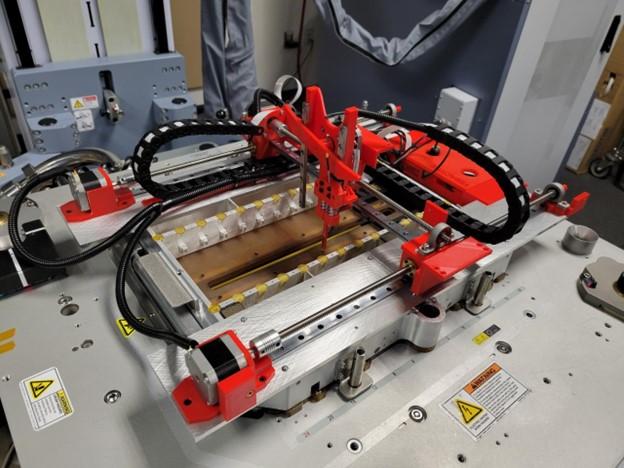
04 · Mechatronics · closed-loop automation
Senior project · 2023
Programmed force-aware connector mating and automatic tool changes for a published robotic test system.
Independent products

05 · Independent software · real-world recommendations
Released independent product
Released an iOS and web product that turns environmental modeling into useful outdoor recommendations.

06 · Independent prototype · participation systems
Independent product prototype
Prototyped beginner-friendly sessions, partner perks, and booking states for real-world movement.
Academic explorations
Relevant technical studies, kept visibly separate from professional and flagship project work.

DTU coursework · 2025
Robotics coursework across ROS2 occupancy-grid mapping, LiDAR and GNSS/IMU data, point-cloud workflows, and Crazyflie / OptiTrack controller validation.

Advanced deep learning coursework · 2025
A PyTorch U-Net diffusion study using one-hot tile representations, with attention to why image metrics alone do not capture structural validity or playability.